From October 23 to 25, the Global Developers Pioneer Summit 2026 (GDPS 2026) and the International Embodied Intelligence Competition (IEIC) were held in Shanghai. NeoteAI Tech Co., Ltd. (NeoteAI) joined forces with the Institute of Trustworthy Embodied Artificial Intelligence at Fudan University to form a joint team and compete in the Quality Inspection event, securing first place and the First Prize in the category.
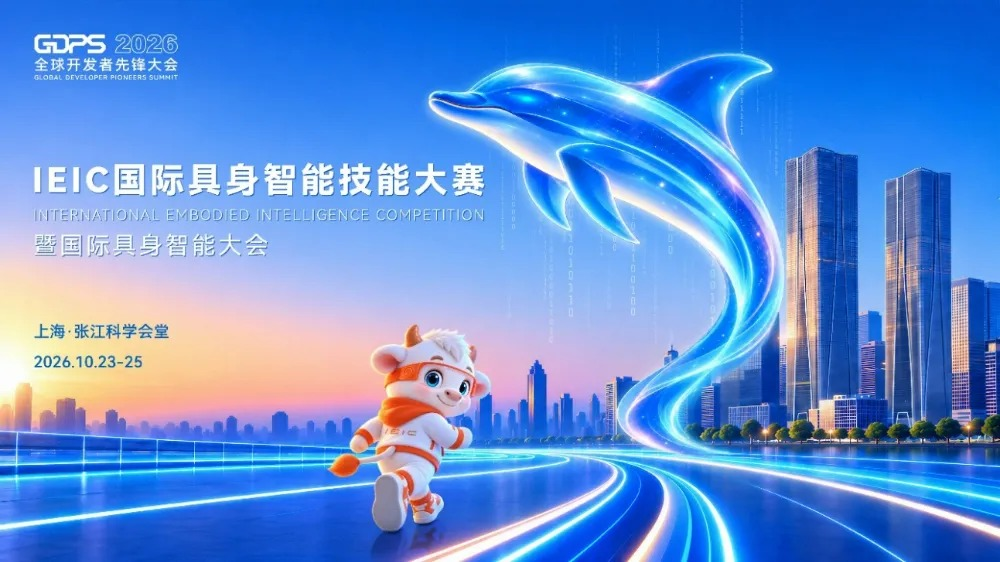
Focusing on Real-World Scenarios to Validate Complex Task Execution Capabilities
As a key component of GDPS 2026, the International Embodied Intelligence Competition focused on three major sectors: industrial applications, service applications, and specialized operations. Featuring nine competition tracks and 23 events, the competition attracted more than 800 teams. With a strong emphasis on real-world scenarios, the competition evaluated robots' capabilities in perception and understanding, task planning, dexterous manipulation, and system coordination in complex environments, aiming to advance embodied AI from technology demonstrations to practical applications.
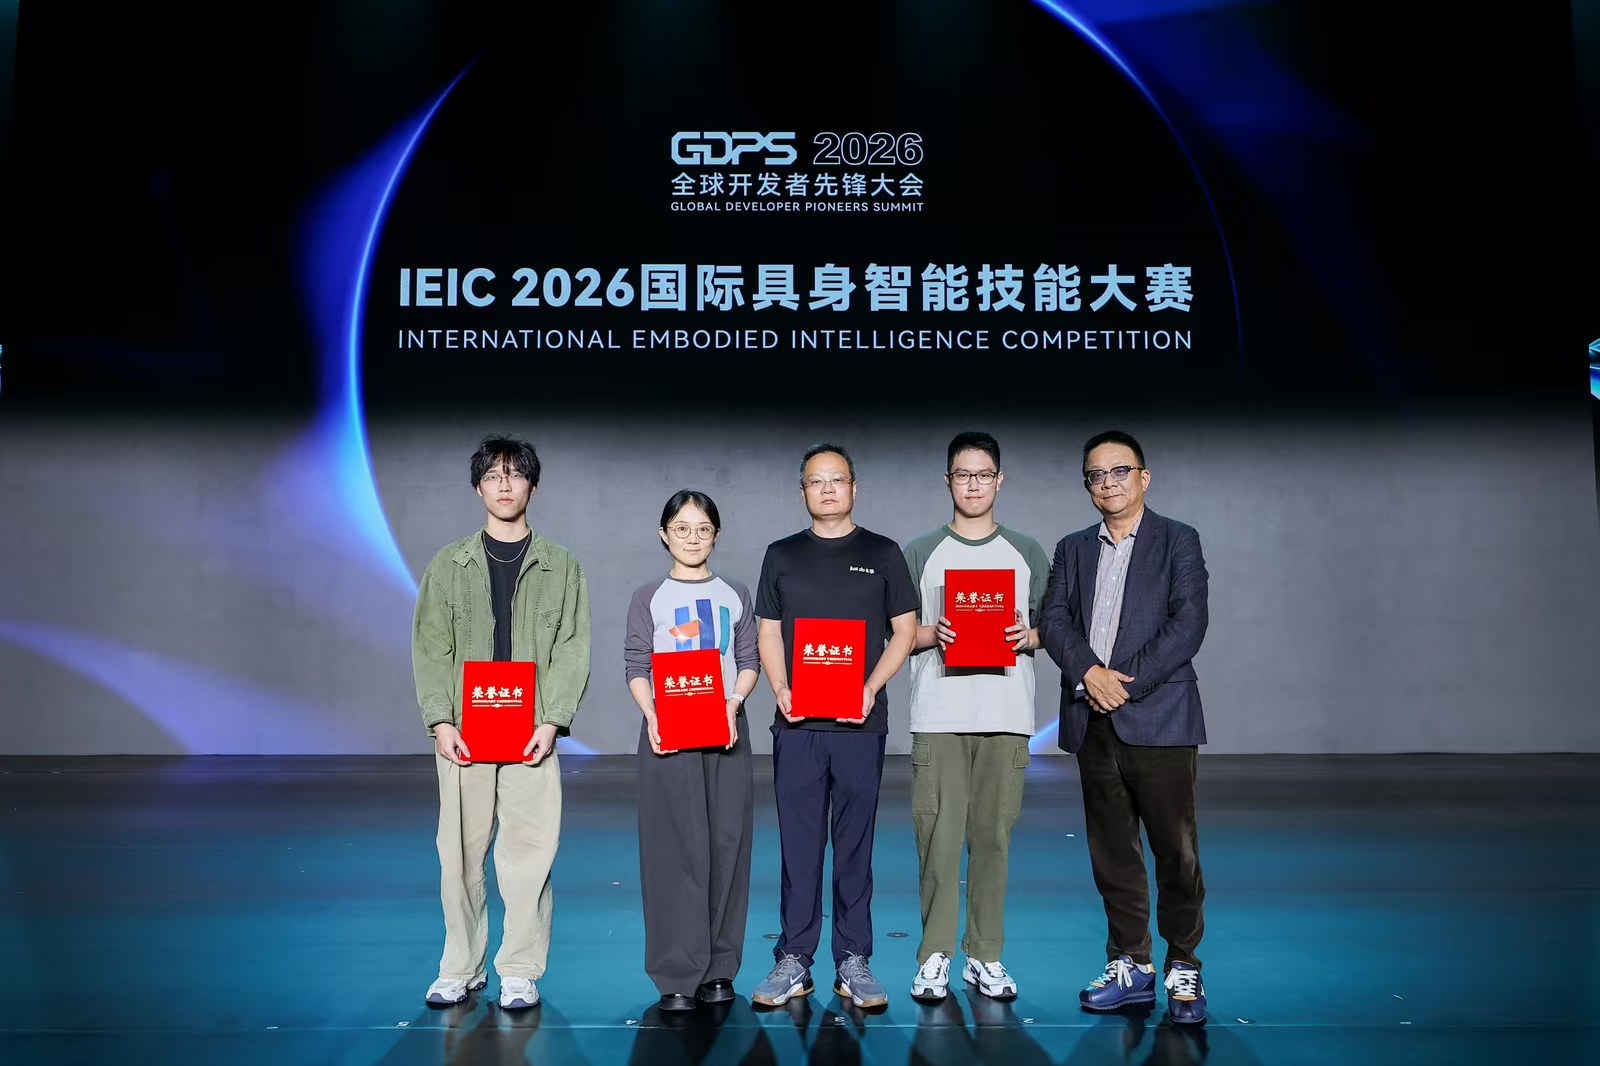
Award Ceremony of the International Embodied Intelligence Competition
In this competition, NeoteAI and the Institute of Trustworthy Embodied Artificial Intelligence at Fudan University formed a joint team to participate in the Quality Inspection event. Designed around real-world industrial quality inspection workflows, the event required robots to perform a continuous sequence of operations involving milk tablet samples, including sample collection, weighing and preparation, centrifuge loading, sample retrieval and placement, status inspection, and classification and sorting. Together, these steps formed a complete closed-loop quality inspection workflow. The multi-stage, long-horizon task posed significant challenges to the robots' multimodal perception, precise grasping, manipulation stability, and long-horizon task planning capabilities.
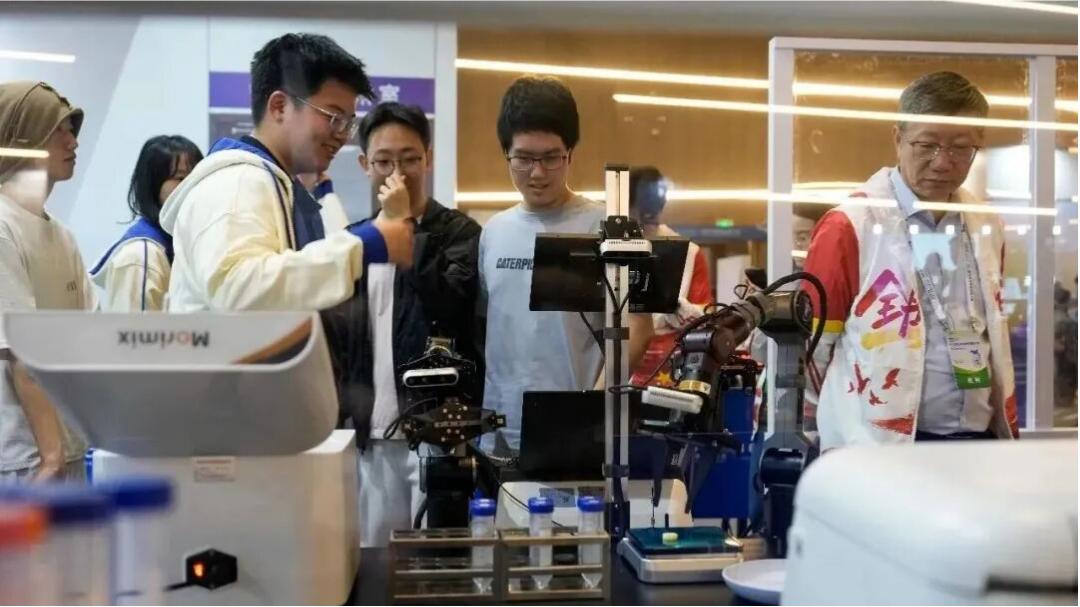
On-site Competition at the Quality Inspection Event
To address these complex challenges, the joint team developed an intelligent embodied dexterous manipulation system based on a general-purpose model. By integrating task decomposition, real-time perception, and motion planning, the system enabled a closed-loop workflow encompassing task understanding, action execution, and outcome feedback, demonstrating the robot's autonomous manipulation capabilities in complex, sequential tasks.
The team's performance in the competition highlighted its technical expertise in tactile embodied AI models, robotic dexterous manipulation, complex task execution, and system integration. It also demonstrated the potential of deeply integrating tactile perception with embodied AI models to enhance robots' autonomous decision-making, dexterous manipulation, and complex task execution capabilities, providing practical validation for the deployment of embodied AI technologies in real-world applications such as industrial quality inspection.
Looking ahead, NeoteAI will continue to advance embodied AI models and robotic dexterous manipulation technologies, further enhancing robots' capabilities in task understanding, autonomous planning, and precise execution in complex environments. The company aims to drive embodied AI beyond individual skill demonstrations toward the autonomous completion of complex tasks, accelerating its real-world deployment in industrial manufacturing, modern agriculture, service robotics, and other application scenarios.