

Category | Specification | Details |
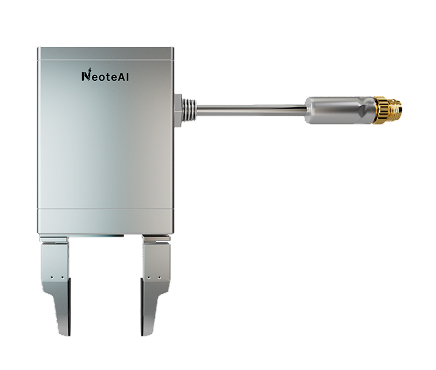
Physical form | Fingertip dimensions | 55 mm × 20 mm × 20 mm (customization supported) |
Weight | < 25g | |
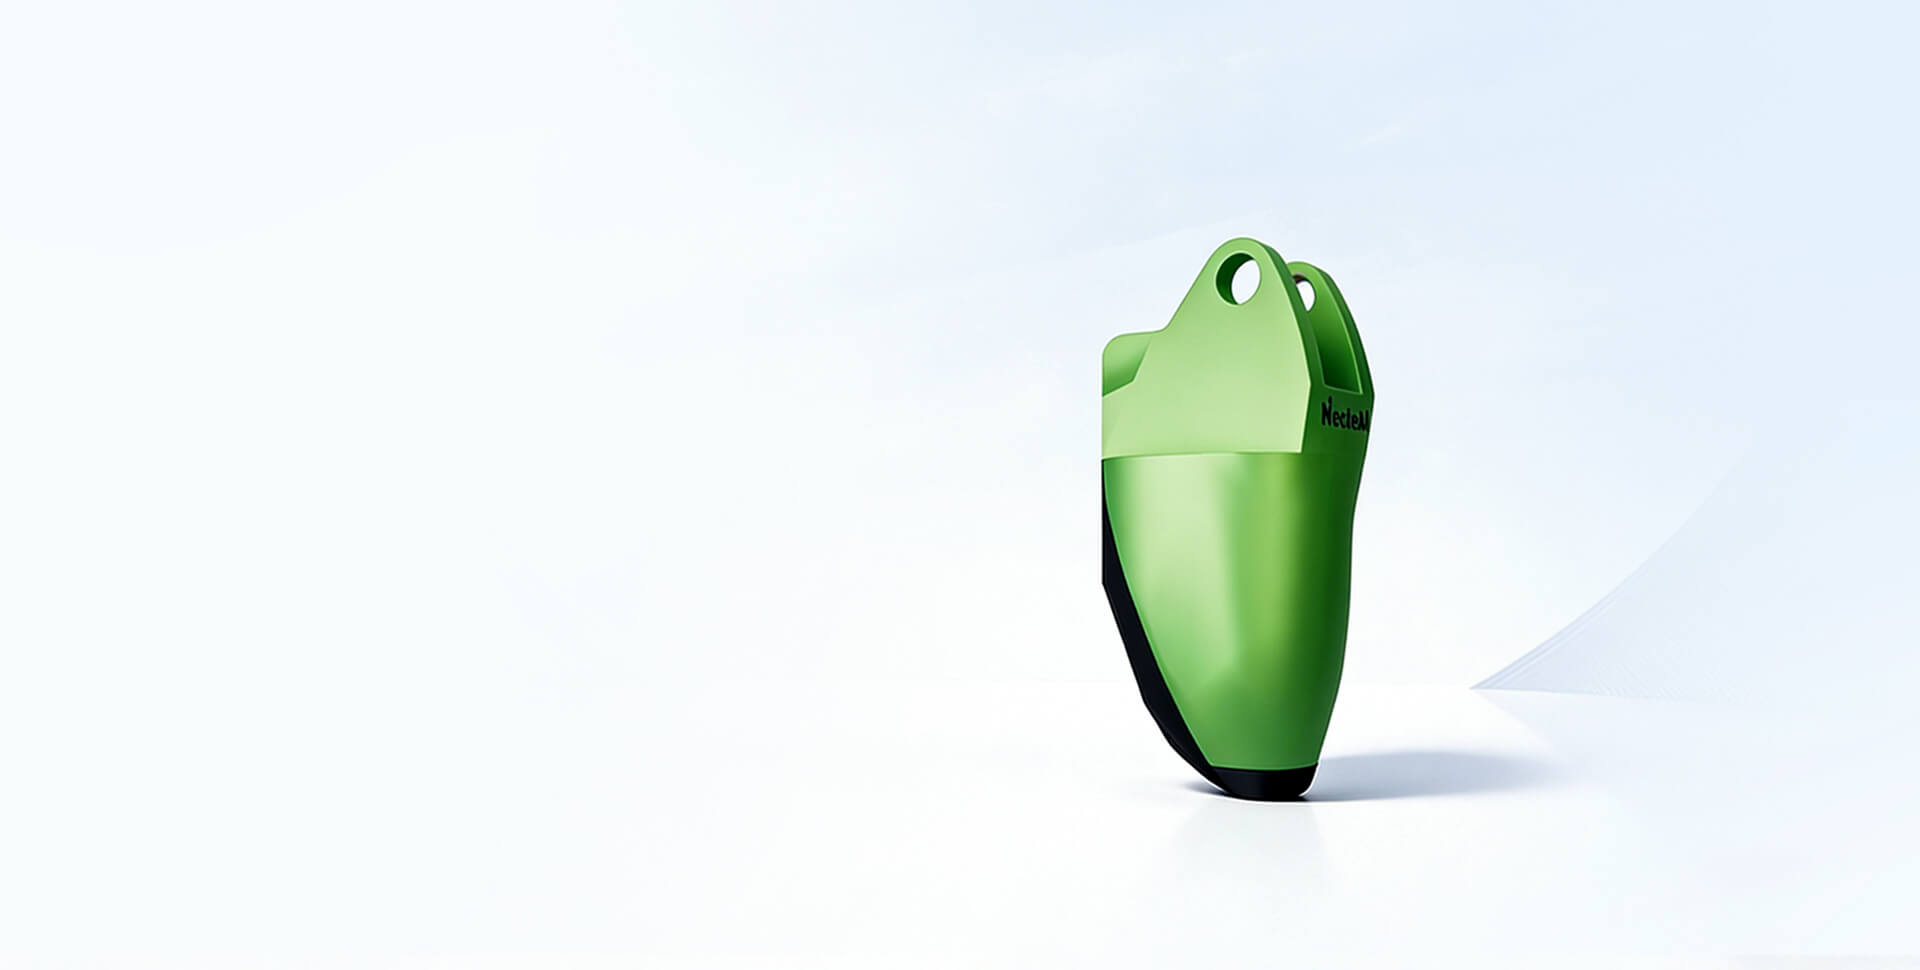
Sensing area | Covers the fingertip pad and the top of the fingertip, approx. 15 mm × 25 mm in total | |
Tactile layer material | Custom curved silicone (replaceable) | |
Sensing performance | Spatial resolution | ~40 μm / pixel (after curved-surface projection) |
Force measurement range | Normal force: 30 N; tangential force: 10 N; average error 0.05 N (customizable) | |
Minimum force threshold | < 0.1 N | |
Curved-surface characteristics | Supports rolling-contact detection and curvature adaptation | |
Compatibility | Compatible hand models | Linkerbot, DexRobot, Jodell Robotics |
Connection type | Flexible FPC ribbon / ultra-fine coaxial cable (easy to route through finger joints) | |
Software interface | Data output | Unwrapped tactile image, 3D contact point cloud, contact force vector |