As embodied AI rapidly advances from algorithm development to real-world applications, the availability of high-quality, multimodal, and scalable data is becoming a critical foundation for advancing robotic manipulation capabilities.
Recently, NeoteAI officially launched NeoData, its multimodal embodied AI data marketplace. Powered by its proprietary embodied AI data service platform for dexterous manipulation and a multimodal data collection system integrating vision, tactile sensing, and motion trajectories, NeoData continuously provides high-quality embodied AI datasets spanning diverse scenarios, tasks, and robotic embodiments to support the training of embodied AI foundation models.
To date, NeoteAI has accumulated over 2 million embodied AI task data records, representing more than 50,000 hours of data and covering over 1,000 tasks. The datasets span a wide range of real-world dexterous manipulation scenarios, including industrial manufacturing, consumer electronics (3C), household services, scientific research, logistics and warehousing, commercial retail, office environments, and food services. They encompass core robotic tasks such as assembly and insertion, sorting and material handling, deformable object manipulation, folding and organization, and pick-and-place operations.
From Simply Collecting Data to Capturing More Complete, Precise, and Scalable Data
Behind NeoData is NeoteAI's continuously evolving embodied AI data service platform, designed specifically for dexterous manipulation.
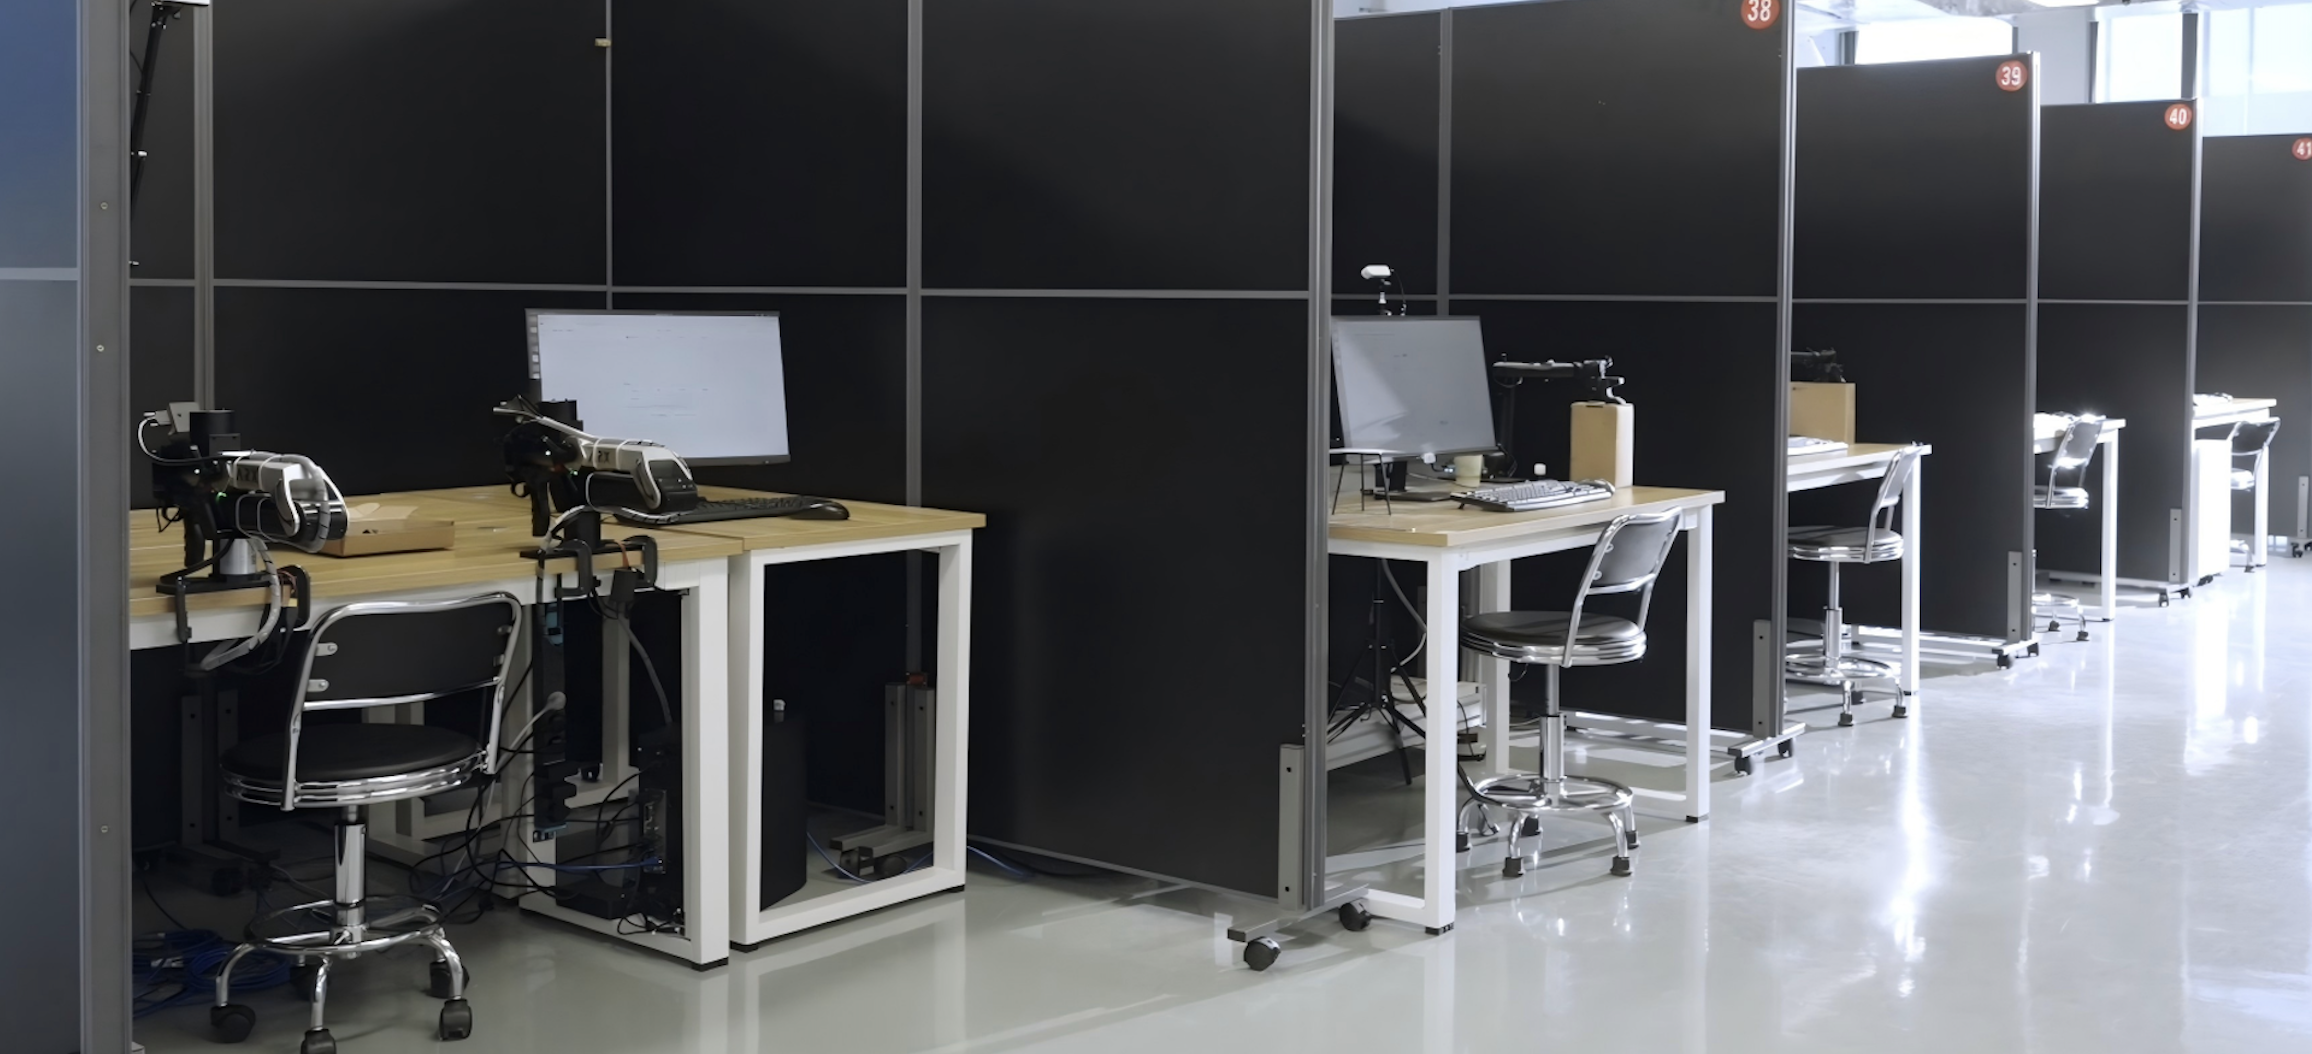
The company has established a dedicated visual-tactile embodied AI data collection facility covering over 1,000 square meters, while also collaborating with partners to collect data in real-world environments.
Focusing on the demands of dexterous manipulation, the platform supports a broad range of tasks, including non-rigid object manipulation, flexible material handling, precision insertion and removal, grasping, and general-purpose manipulation, with its coverage of tasks and scenarios continuously expanding.
Currently, the platform is capable of collecting more than 1,000 hours of high-quality, usable data per day. Through standardized and scalable data production processes, it provides a stable and reliable data supply for embodied AI foundation model training.
Throughout the data production process, NeoteAI has established a comprehensive pipeline covering task design, data collection protocols, data cleaning, quality review, and multi-level annotation. Collected data undergoes continuous inspection and filtering to ensure that tasks are aligned with real-world requirements and that delivered datasets are well-structured, valid, and ready for model training. By leveraging a unified production workflow, NeoData maintains data quality and delivery efficiency while scaling up data production.
Unlike conventional data collection approaches that primarily focus on visual observations and action trajectories, NeoteAI places greater emphasis on visual-tactile perception and interaction states during physical contact between robots and the real world.
The data captures not only "what the robot sees and does," but also "what the robot touches and how contact conditions change." This provides richer information for models to understand fine-grained manipulation processes involving contact, deformation, and slippage.
These capabilities also lay the foundation for building larger and more diverse visual-tactile manipulation datasets in the future.
Real-Robot Data Collection + UMI: Supporting Data Needs Across Different Stages
To balance data collection efficiency, cross-embodiment adaptability, and physical realism, NeoData has established a dual-track data collection framework combining real-robot data collection with the Universal Manipulation Interface (UMI).
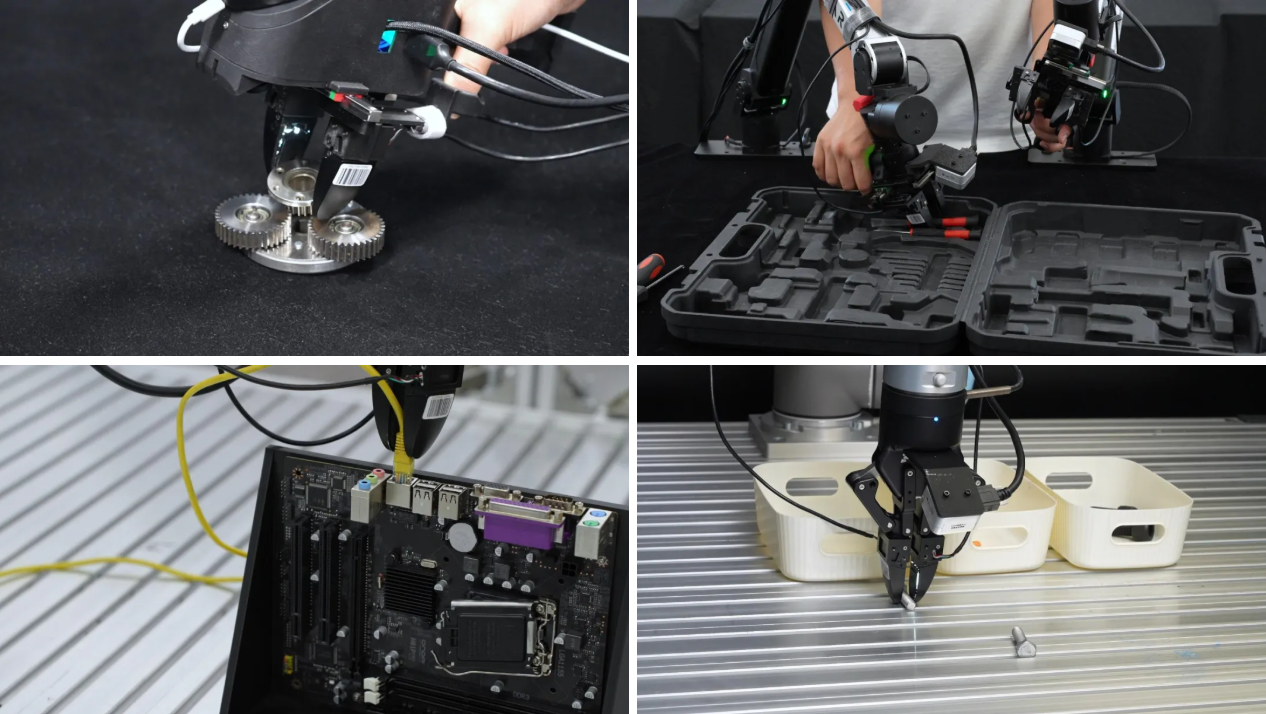
For real-robot data collection, the platform supports multiple methods, including isomorphic teleoperation, VR-based teleoperation, GELLO, and 3D mouse control. These approaches directly capture multimodal interaction data during actual robotic task execution, supporting manipulation policy training and real-world deployment.
For UMI-based data collection, NeoteAI has independently developed UMI devices specifically designed for visual-tactile data acquisition. Without relying on a specific robotic arm platform, these devices enable rapid collection of multimodal data, including visual observations, visual-tactile feedback, and action trajectories, through human demonstrations. This approach provides greater flexibility across different objects, environments, and manipulation tasks.
The two approaches complement each other. Real-robot data strengthens the physical consistency of robotic execution, while UMI improves data collection efficiency and scalability across diverse scenarios. Together, they form the foundation of NeoData's scalable and systematic data production framework.
NeoData: Turning the Real World into a Training Ground for Robots
From precision insertion in industrial assembly to clothing folding in household environments, and from sorting and material handling in logistics facilities to object organization in commercial services, deploying robots in the real world requires far more than simply identifying targets.
Robots must also understand and respond to contact, applied forces, deformation, slippage, and sequential action decisions in complex environments.
To support the training requirements of different models and robotic embodiments, NeoData integrates multi-scenario task datasets, visual-tactile information, and real-world execution data into a unified data supply system.
Customers can select standardized dataset products directly from the marketplace or request customized data collection and specialized data services based on their robotic platforms, task types, application scenarios, data modalities, and annotation requirements.
From initial task definition and data collection to cleaning, annotation, and final delivery, NeoData provides end-to-end data services that help customers reduce redundant infrastructure investment and obtain training-ready data more efficiently.
Standardized datasets and customized services can be flexibly combined to meet specific requirements, offering cost-effective solutions for teams of different sizes.
Looking ahead, NeoteAI will continue to expand its scenario coverage and data scale while further enhancing its UMI solutions, real-robot data collection capabilities, cross-embodiment infrastructure, and visual-tactile multimodal data systems.
By enabling more high-quality embodied AI data to enter the model training pipeline, NeoteAI aims to establish data as a foundational infrastructure for the continuous evolution of embodied intelligence.
NeoData Multimodal Data Marketplace: Connecting High-Quality Embodied AI Data with Real-World Robotic Intelligence.
We welcome partners from the embodied AI, robotics, and related industries to explore NeoData and discover our data products and services.
NeoData offers customized data collection, dedicated acquisition projects, and specialized data service solutions tailored to different robotic platforms, task requirements, and application scenarios.
Customers can flexibly select service packages based on their model training objectives and budgets.
Contact us to explore partnership opportunities.